Willkommen. Schön, sind Sie da!
0
IHR WARENKORB IST AKTUELL LEER.
Haben Sie noch nichts passendes gefunden? Stöbern Sie durch unser komplettes Sortiment.
Oder melden Sie sich an bzw. registrieren Sie sich.
Ihre Vorteile
- Kostenlose Lieferung
- Kauf auf Rechnung
- Ex Libris Tiefpreis
- Filiallieferung und 650+ Abholorte
- Rabatt-Bons als Club-Mitglied
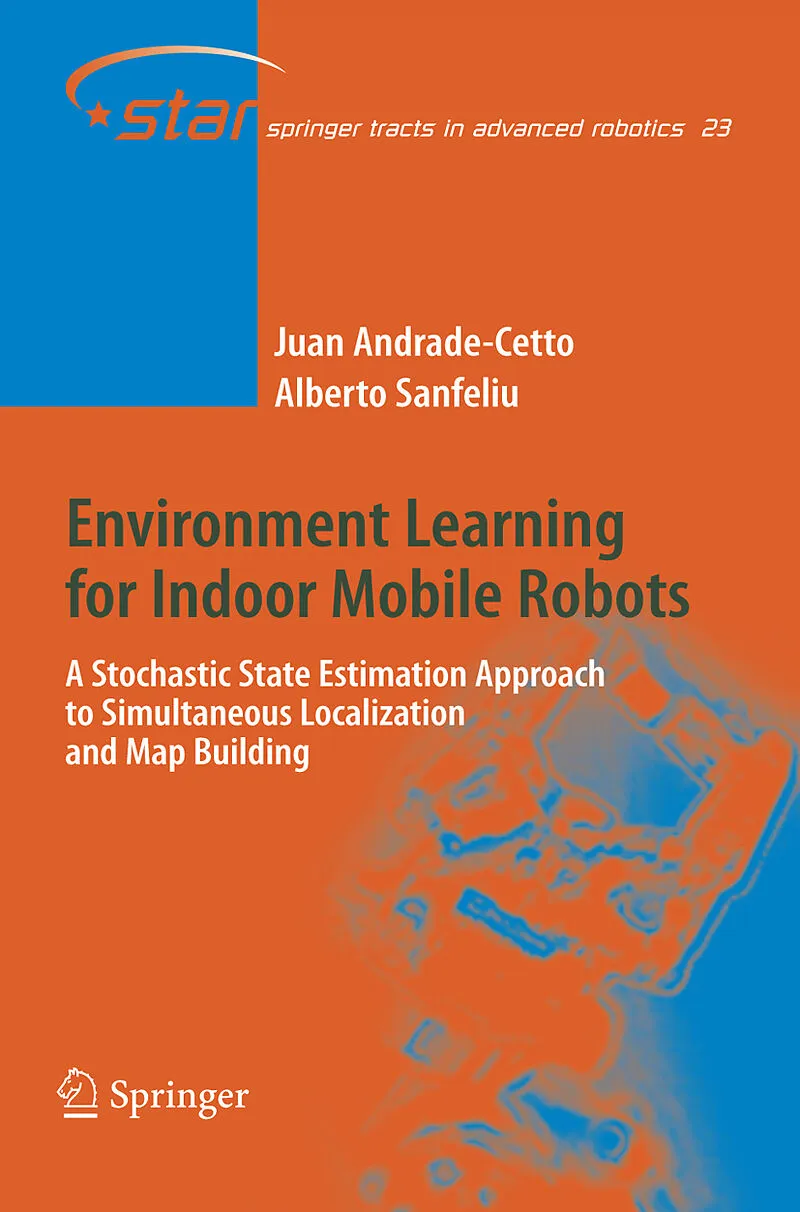
Environment Learning for Indoor Mobile Robots
Rabatt
Beschreibung
This monograph covers theoretical aspects of simultaneous localization and map building for mobile robots, such as estimation stability, nonlinear models for the propagation of uncertainties, temporal landmark compatibility, as well as issues pertaining the c...
Format auswählen
- Kartonierter EinbandCHF 123.10
- Fester EinbandCHF 144.15
Kartonierter Einband
CHF 144.80
CHF123.10Fester Einband
CHF 169.60
CHF144.15-15%Sie sparen CHF 21.70
CHF123.10
Print on Demand - Exemplar wird für Sie gedruckt.
Kostenlose Lieferung
Kein Rückgaberecht
Weitere Produkte aus der Reihe "Springer Tracts in Advanced Robotics"
Band 23![Kartonierter Einband Environment Learning for Indoor Mobile Robots von Juan Andrade Cetto, Alberto Sanfeliu]()

15%
- Environment Learning for Indoor Mobile Robots
- Juan Andrade Cetto, Alberto Sanfeliu
Sie sind hier.


